Sarathi V1.2
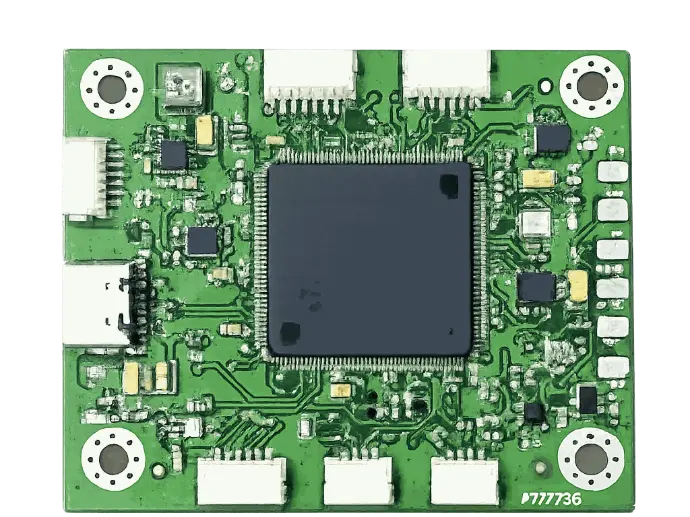
Sarathi V1.2 is a 4-layer UAV flight controller built on the STM32H743 (Cortex-M7, 480 MHz, 2 MB flash, 1 MB RAM). It carries a TDK ICM-40609-D IMU, Bosch BMP390 barometer and ST IIS2MDC magnetometer, drives ten PWM outputs (eight DShot-capable ESC channels plus two auxiliary), and brings GPS, telemetry, RC, CAN, I²C and spare UART/ADC ports out on JST GH connectors. It is designed to work with EEPL ESCs and the EEPL power module.
Available to buy online on BotBhidu.com. Buy on BotBhidu Download User Manual (PDF)
Key Performance Metrics
Cortex-M7 Processor
PWM Outputs
Module Mass
Core Capabilities
PX4 and ArduPilot compatibility
The on-board IMU, barometer and magnetometer all have upstream PX4 and ArduPilot drivers.
CAN bus for DroneCAN
FDCAN port with TJA1051 transceiver and on-board 120 Ω termination for DroneCAN ESCs and peripherals.
microSD flight logging
4-bit SDMMC microSD slot for flight logs, parameters and mission data.
Technical Overview
STM32H743ZIT6, Cortex-M7, 480 MHz, 2 MB flash
TDK ICM-40609-D, 6-axis, SPI
Bosch BMP390, I²C
ST IIS2MDC, I²C
5 (GPS, telemetry with RTS/CTS, RC, 2 spare)
1 bus on JST GH and pad-out
Battery voltage and current, plus 3 spare
3 GPIO (2 shared with auxiliary PWM), plus safety switch and buzzer
USB-C 2.0 with ESD protection
External GPS port (UART)
5 V (4.5–5.5 V) from USB-C or power module, automatic switch-over